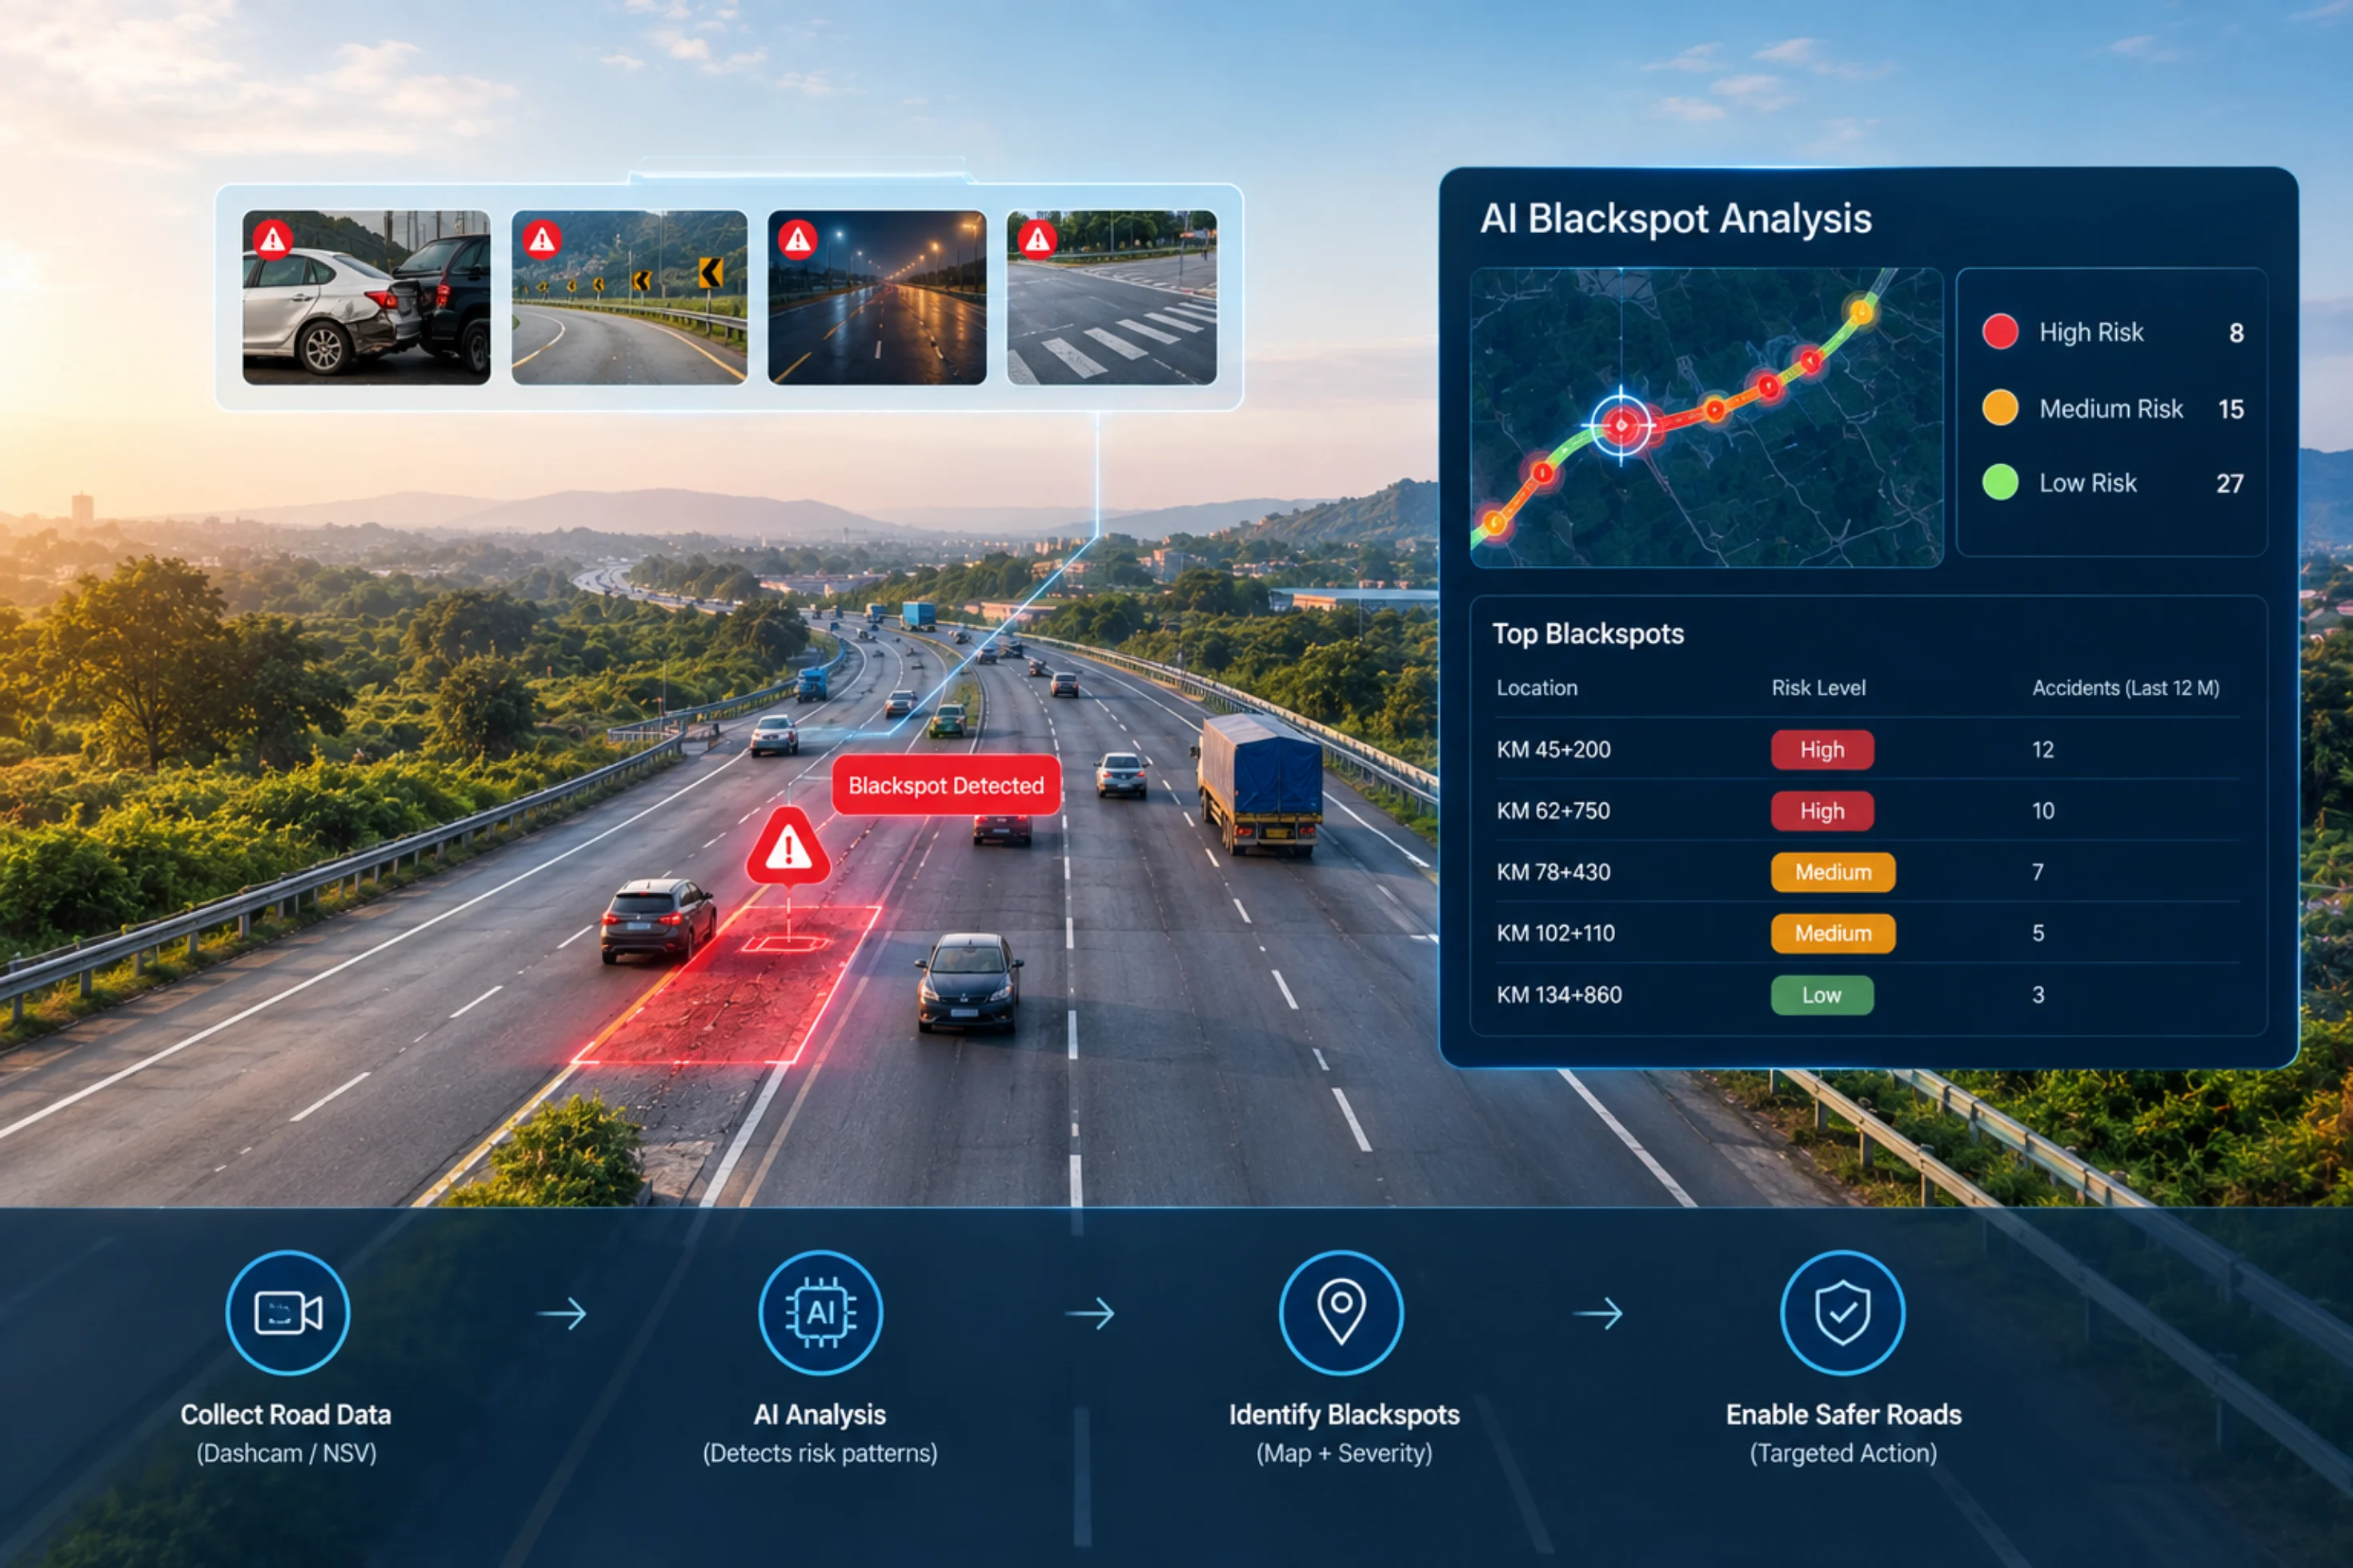
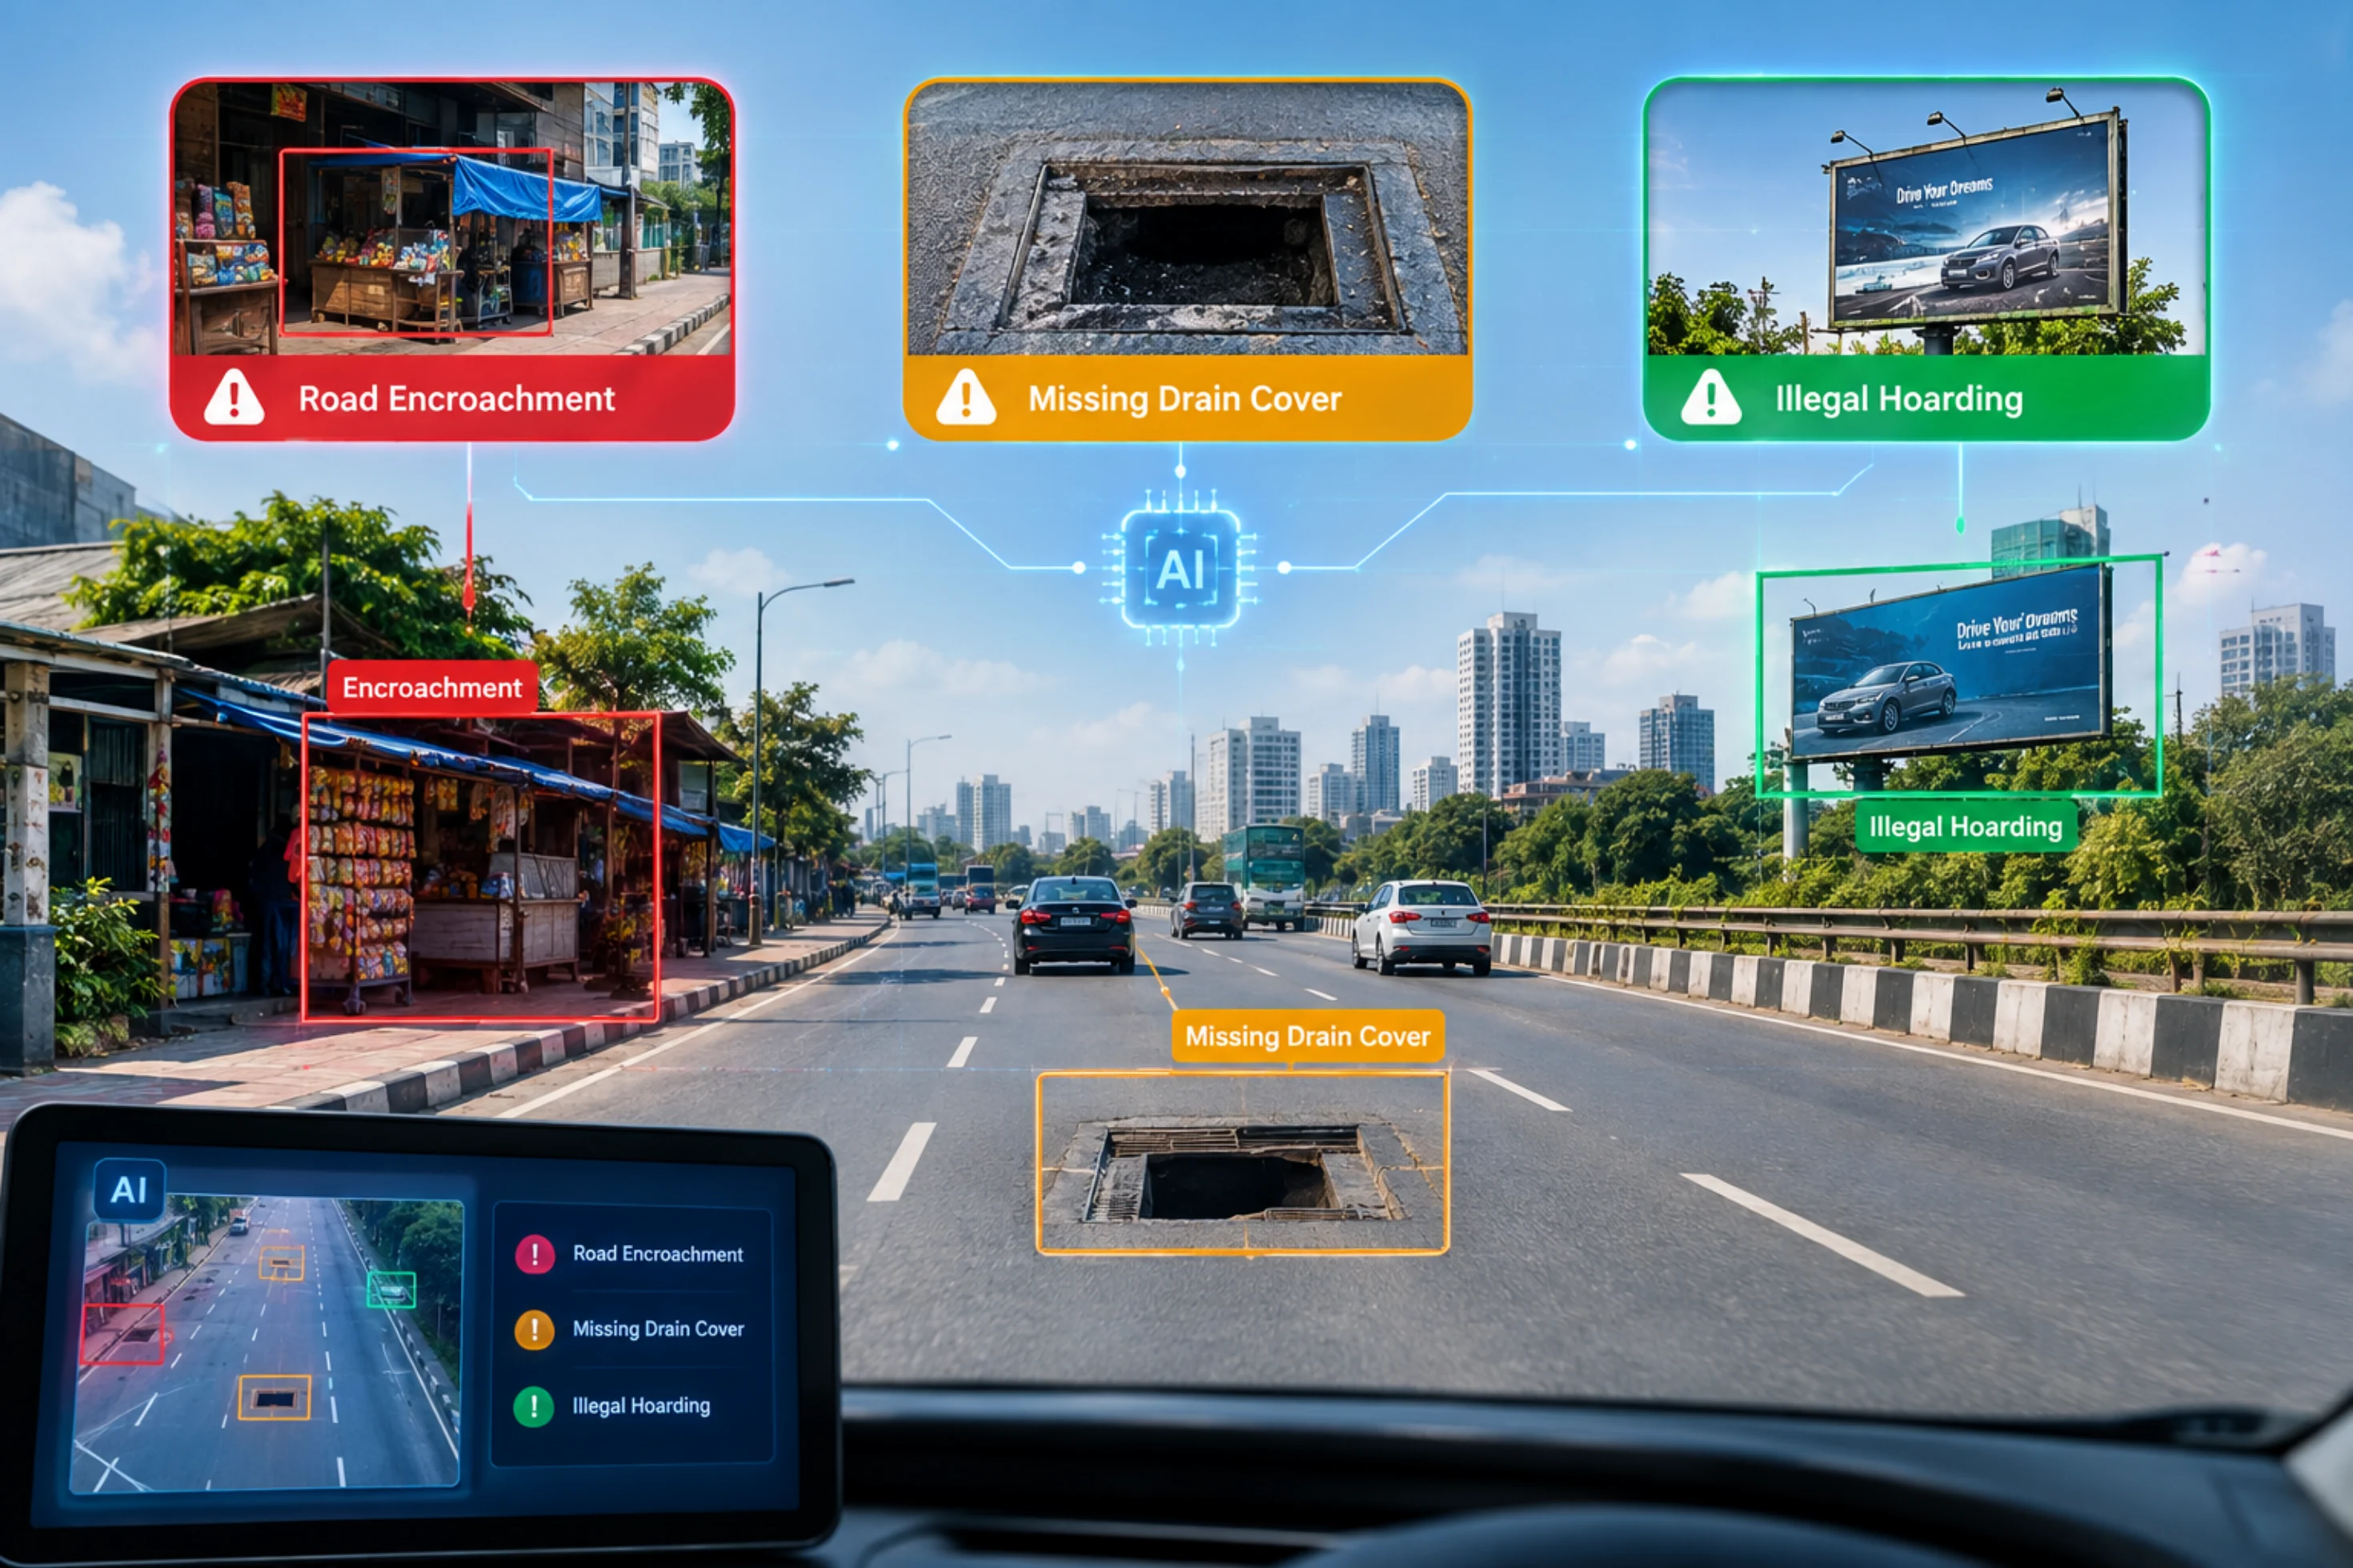
Road damage detection using AI uses computer vision and machine learning to automatically identify and classify pavement damage potholes, cracking, rutting, raveling, and more from images or video captured by cameras mounted on vehicles, drones, or fixed infrastructure. A trained model (typically a convolutional neural network or object detection architecture like YOLO) scans each frame, flags visible damage, classifies its type and severity, and tags it with a precise GPS location. The result is structured, actionable data delivered in a fraction of the time and cost of manual inspection, often supplemented by sensor data (accelerometers, LiDAR) to confirm findings and reduce false positives.
The process starts with imagery and sensor data collected from one or more sources: dedicated survey vehicles with high-resolution cameras and LiDAR, standard fleet vehicles (buses, service trucks) fitted with dashcams, or drones for aerial or hard-to-access coverage.
Captured frames are corrected for lens distortion, filtered to remove unusable images (blur, obstruction, poor lighting), and synchronized with GPS data so every frame ties to a precise location.
Trained computer vision models commonly convolutional neural networks (CNNs) or object detection architectures like YOLO (You Only Look Once) or Faster R-CNN scan each frame to identify damage, drawing a bounding box around it and assigning a classification (pothole, fatigue crack, rutting, etc.) along with a confidence score.
Many systems cross-reference visual detections with accelerometer or vibration sensor data. When a physical impact registers at the same location and moment as a visual detection, confidence in the finding increases significantly this is one of the most effective ways to cut down false positives from shadows, stains, or debris.
Defects defined by deformation rather than shape — rutting, shoving — generally require LiDAR or stereo camera-based 3D surface profiling rather than 2D image analysis alone, since what matters is depth and cross-sectional shape, not just surface appearance.
Detected damage is scored based on size, depth, and density, often mapped to standardized indices like the Pavement Condition Index (PCI) so output remains compatible with established engineering practice rather than existing as a proprietary, incomparable score.
Where the same road segment is captured multiple times, the system consolidates repeated detections into a single, tracked record and monitors whether severity is increasing across successive passes.
Final results are compiled into structured, geotagged data delivered through a dashboard, GIS system, or direct integration with a maintenance work order platform in more advanced deployments, generating repair tickets automatically.
Not every AI road damage detection system performs equally, and the gap usually comes down to a handful of factors:
A system that flags "damage present" without classifying what kind is only partially useful. Classification accuracy directly affects three things agencies actually care about:
Road damage detection using AI works by combining efficient image and sensor capture with trained computer vision models that identify, classify, and score damage automatically turning what used to be slow, manual, inconsistent inspection into fast, consistent, network-wide data collection. The technology's real value isn't just finding damage faster; it's classifying it accurately enough that agencies can act on the right treatment, for the right cause, before a manageable defect becomes an expensive reconstruction project.
RoadVision AI's computer vision models detect and classify the full range of road damage potholes, all major crack types, rutting, raveling, and more — from vehicle-mounted cameras and fleet dashcams, delivering standardized, PCI-compatible severity data your team can act on immediately.
Want to see AI-powered road damage detection applied to your network? Talk to the RoadVision AI team to learn more or request a demo.
AI uses computer vision models trained on labeled road imagery to identify and classify damage potholes, cracking, rutting, and more from camera footage, often combined with sensor data like accelerometers to confirm findings and reduce false positives.
AI can detect potholes, fatigue (alligator) cracking, block cracking, edge cracking, transverse cracking, rutting, raveling, and bleeding, each identified through distinct visual patterns, textures, or 3D surface data.
3. How accurate is AI road damage detection?
Accuracy depends on training data diversity, camera quality, sensor fusion, and vehicle speed, but well-optimized systems can achieve high detection accuracy often above 90% under typical driving conditions.
Not necessarily. Many systems work with standard dashcams mounted on existing fleet vehicles, though dedicated survey vehicles with LiDAR and specialized sensors offer higher precision for structural or depth-based defects like rutting.
Different damage types require different repairs and indicate different root causes, so accurate classification directly affects whether maintenance dollars are spent on the correct treatment.
Detection accuracy can decline in heavy rain, fog, snow, or low light, though systems using sensor fusion and diverse training data are generally designed to maintain reasonable reliability across a range of conditions.
Not entirely. AI handles the bulk of routine detection and classification efficiently, but manual or structural verification often remains valuable for ambiguous findings or high-stakes safety decisions.
Detected damage is typically compiled into structured, geotagged data integrated with GIS systems, maintenance work order platforms, and pavement management software to support prioritized, data-driven repair planning.
The Autonomous Road Engineer
AI-powered road condition monitoring, asset management, & infrastructure intelligence helping agencies move from reactive maintenance to predictive road management.